project / aerial-robotics
Purdue IEEE
Aerial Robotics
I served as Captain and Electrical Lead for a 30+ student team developing a custom UAV for the AUVSI Student Unmanned Aerial Systems competition.
2015–2017Flight controlsTeam leadership
Flight-controller work
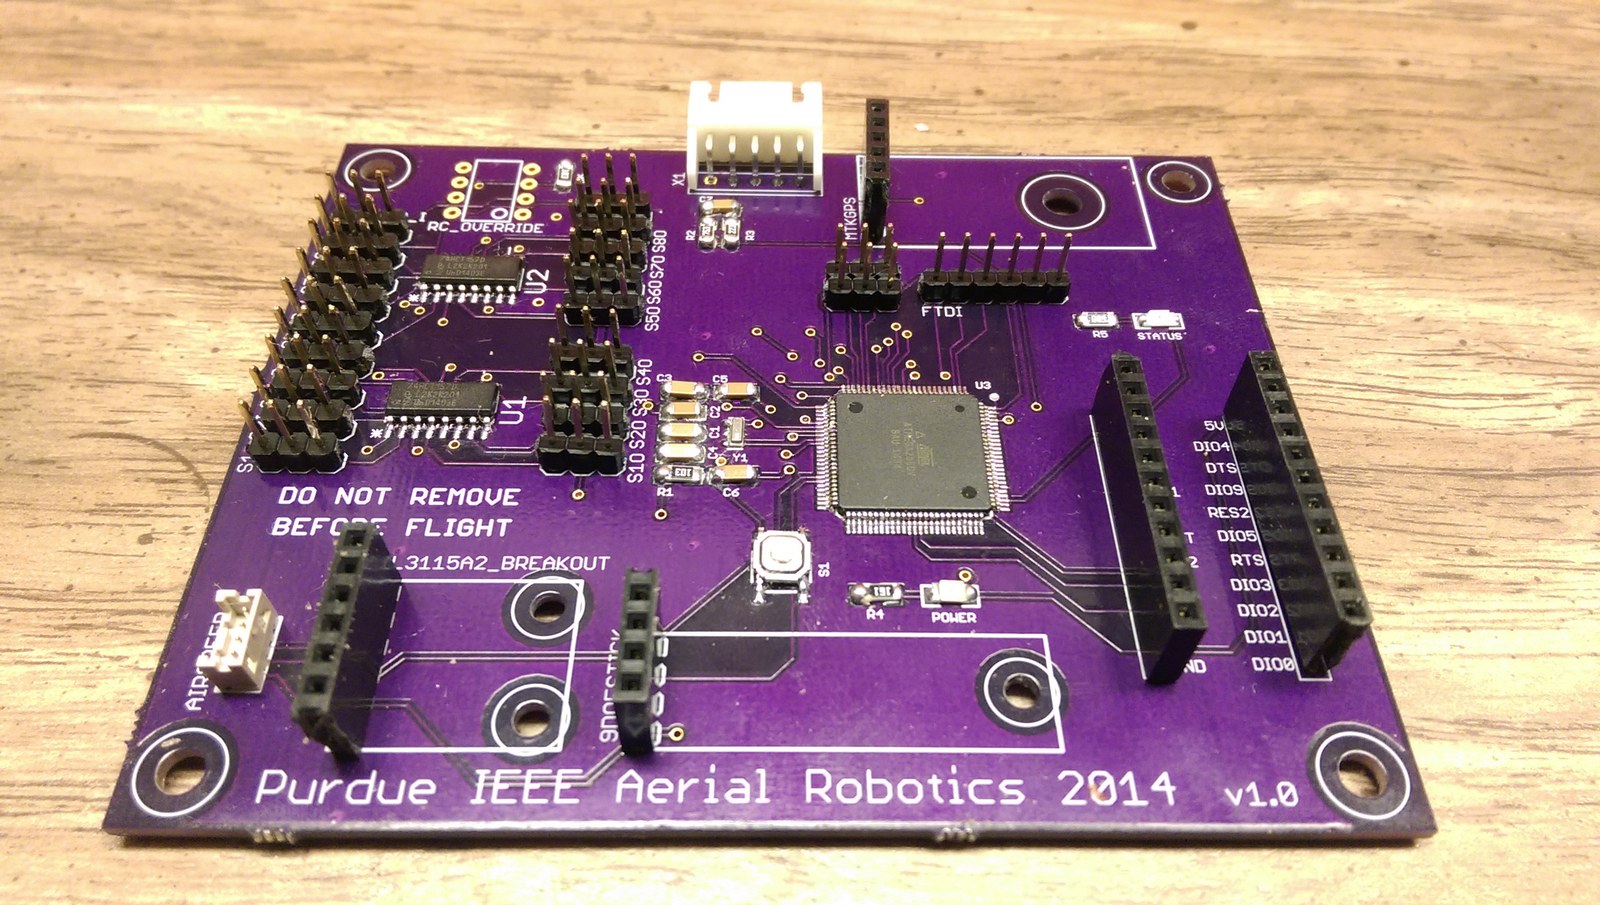
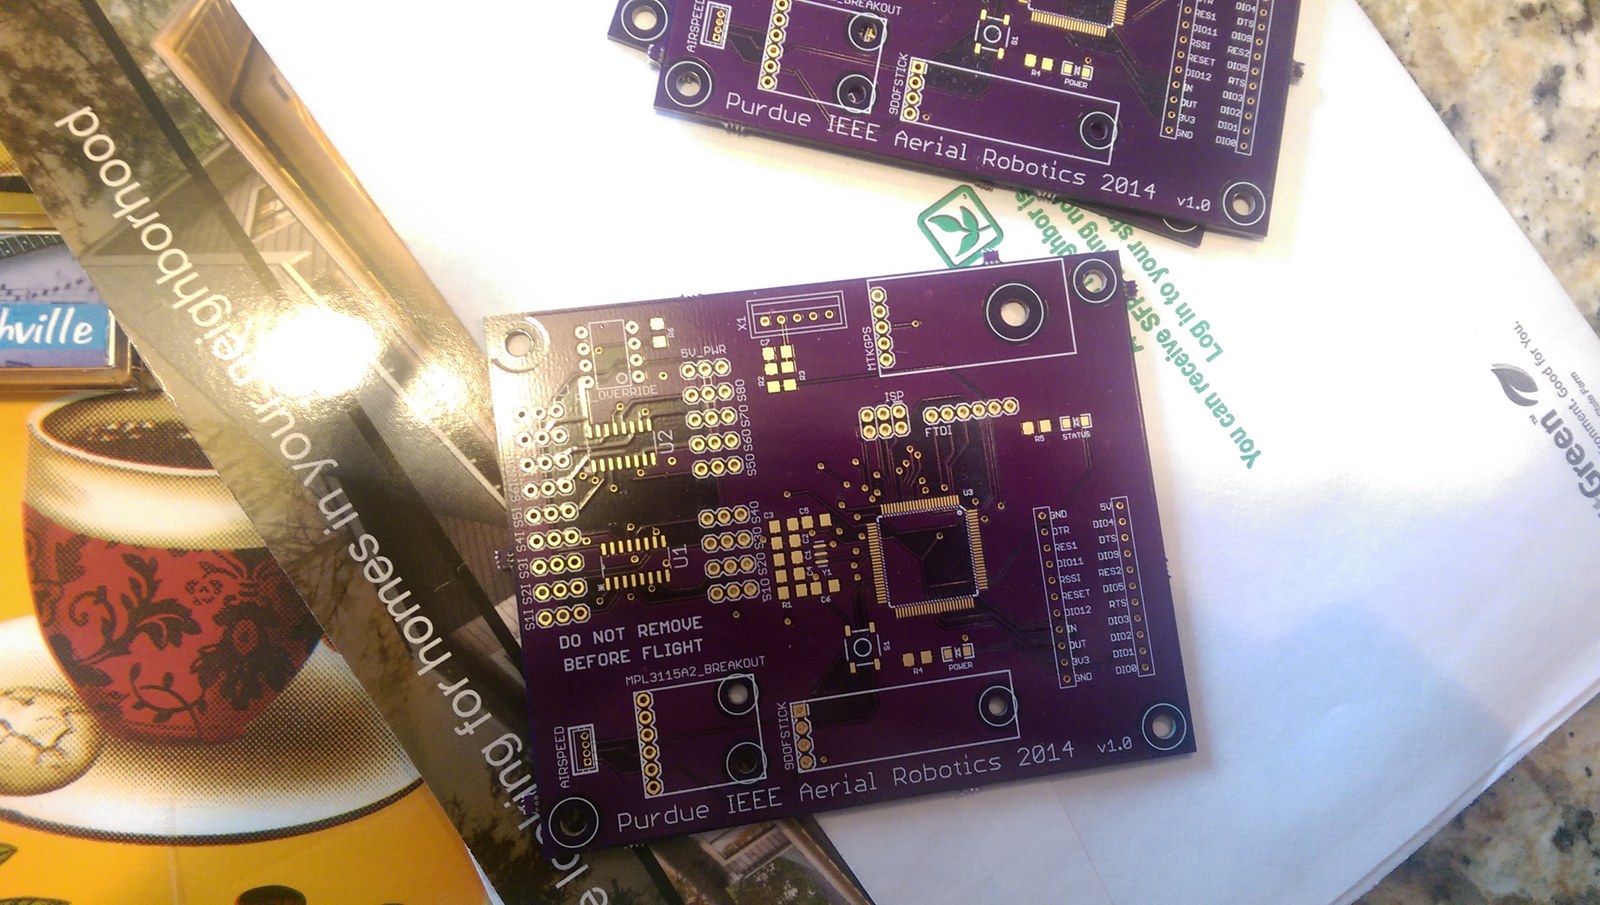
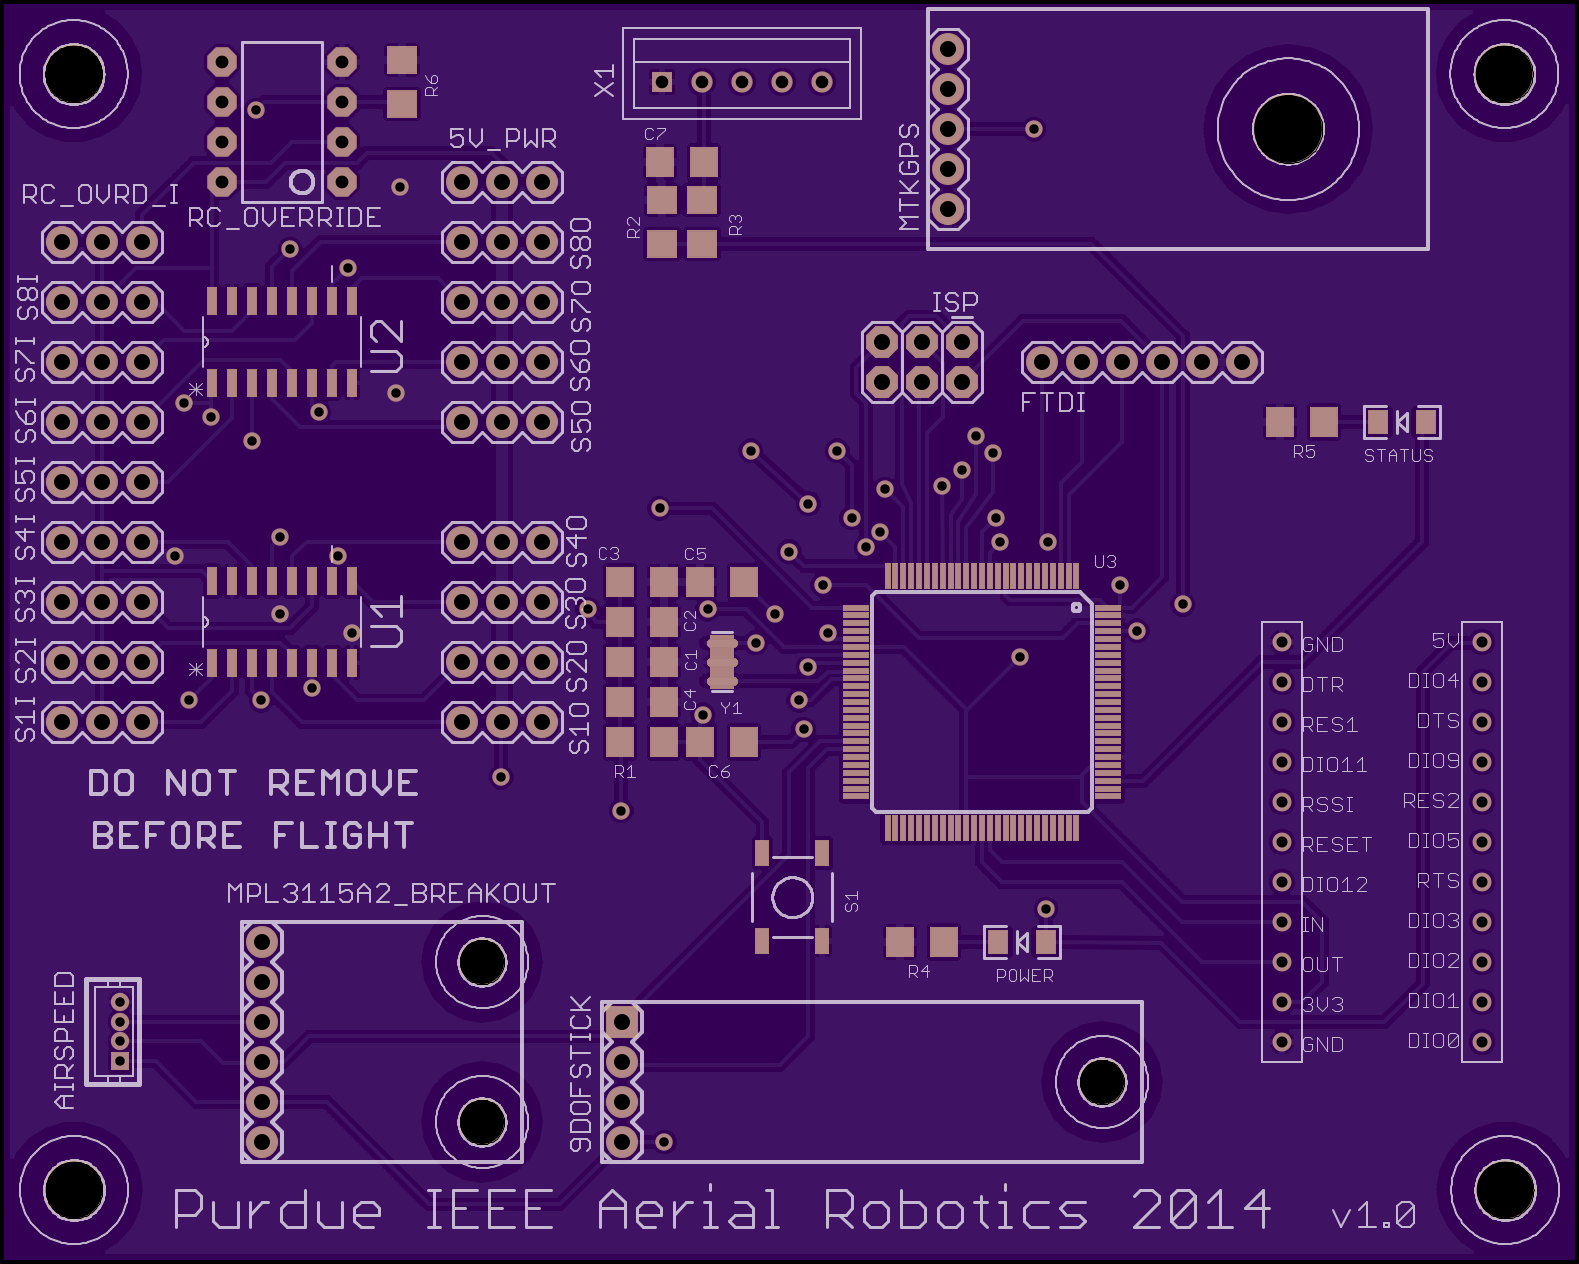
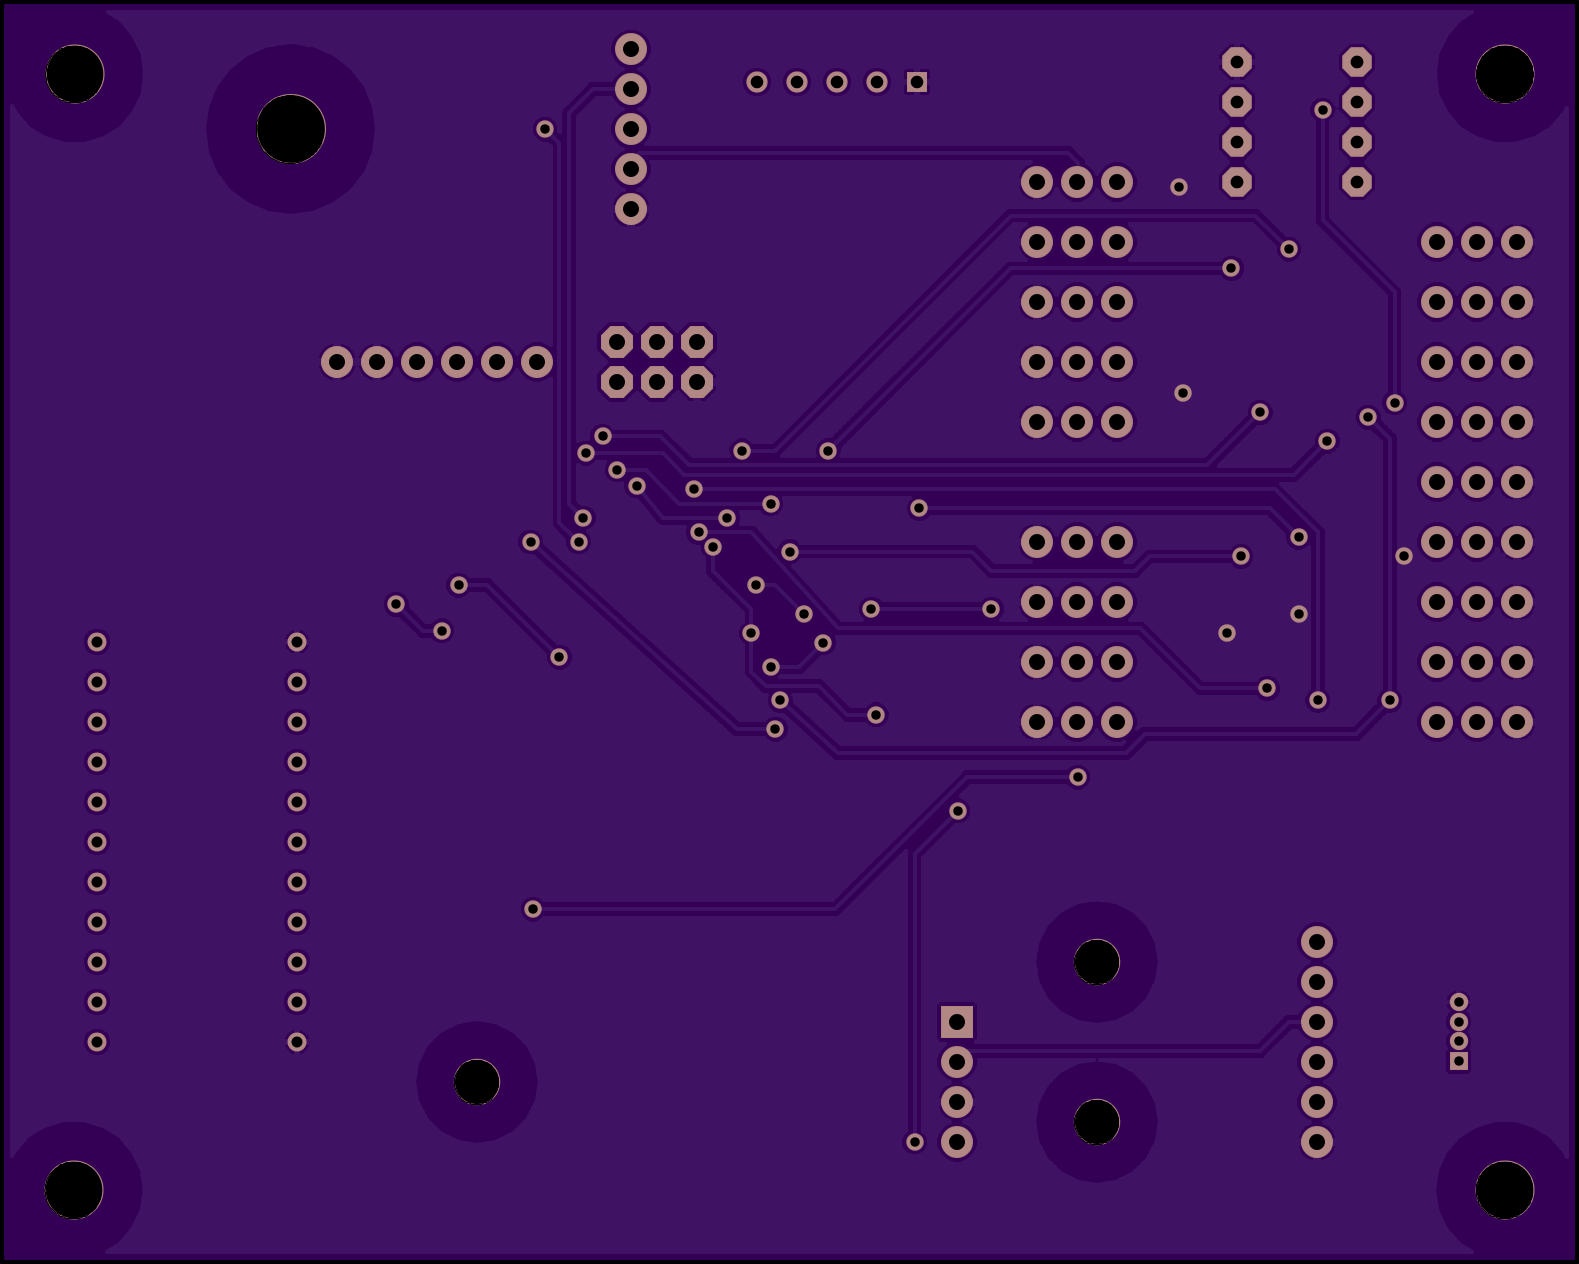
The project combined embedded firmware, electronics, and aircraft integration. My work included sensor and motor-interface firmware along with the design and layout of custom controller hardware.
The team developed its own ARM Cortex-M4 flight controller as the platform evolved. Earlier controller hardware used an ATmega2560 to interface with sensors and the aircraft's servos while running the flight-control algorithms.
Team
Beyond my own hardware and firmware work, I coordinated the electrical team and helped keep a multidisciplinary group moving toward a single aircraft that had to work in the field.