project / robot-arm
Robot Arm
I designed and built this robot arm during my senior year of high school for Science Olympiad. It won first place at both the regional and Tennessee state competitions in 2013.
2013First placeElectromechanical design
Construction
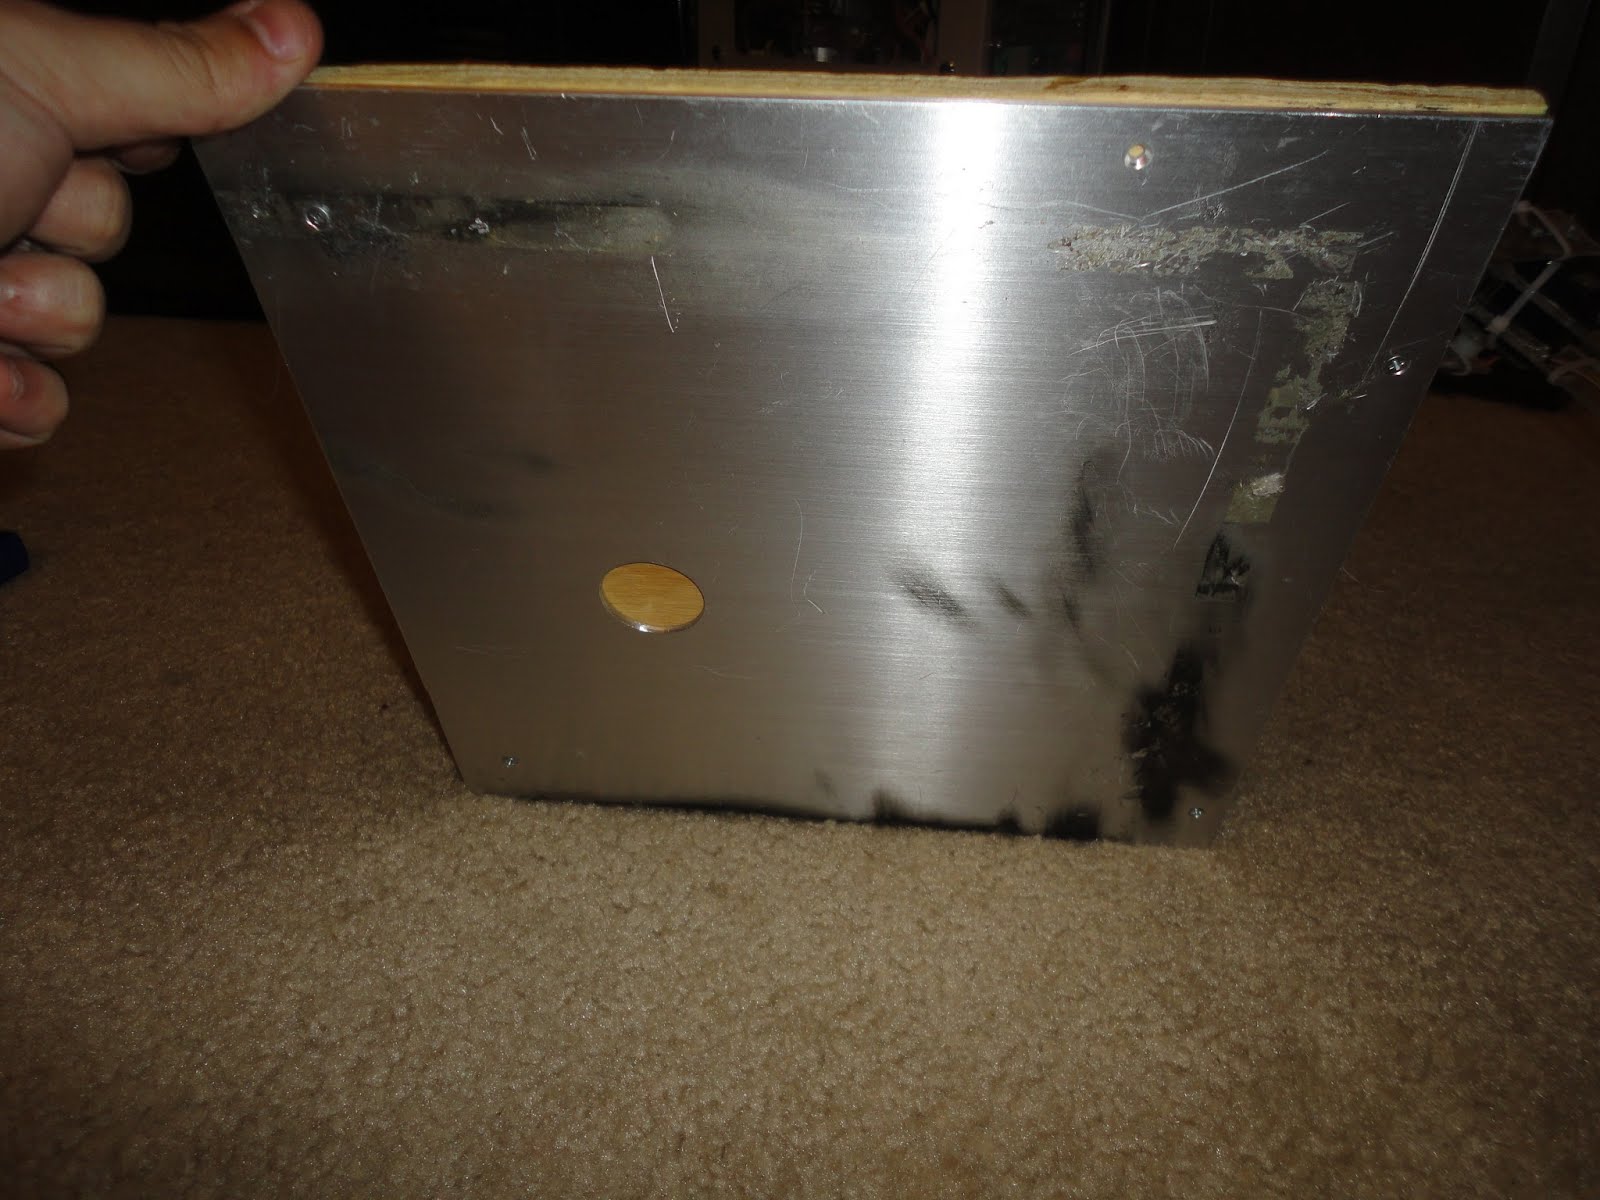
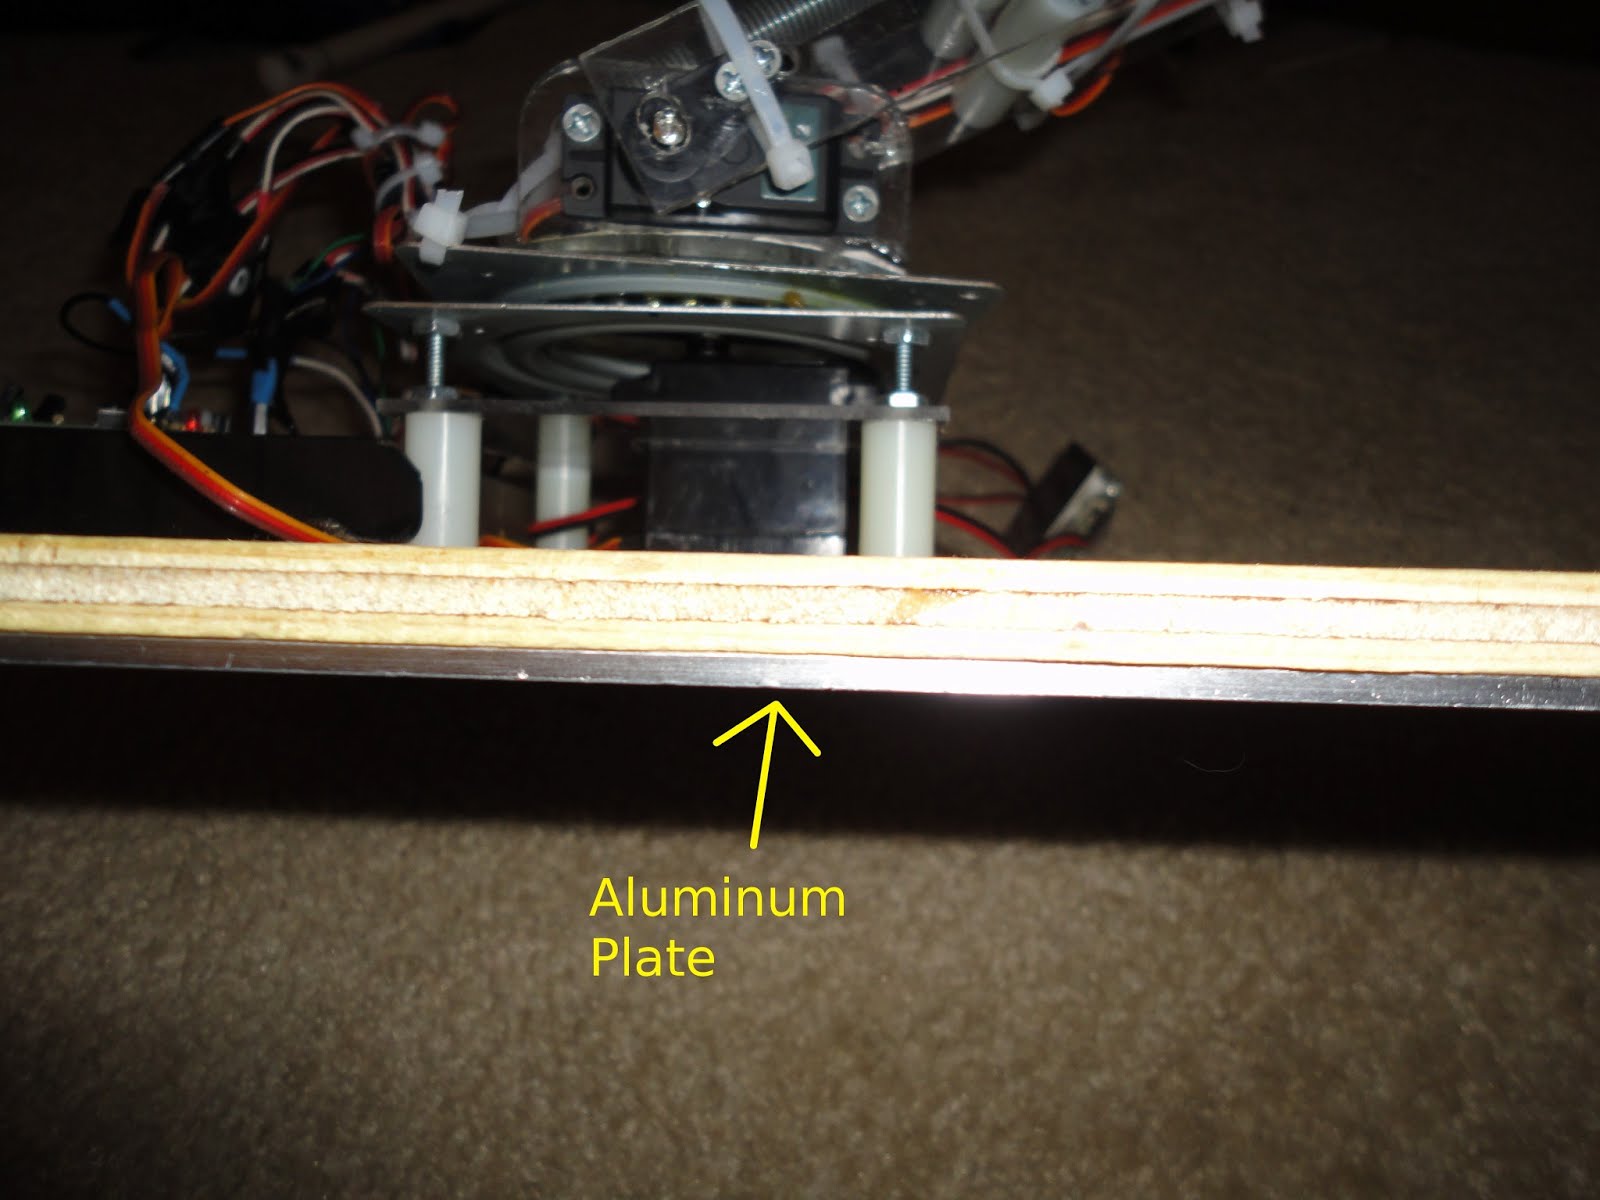
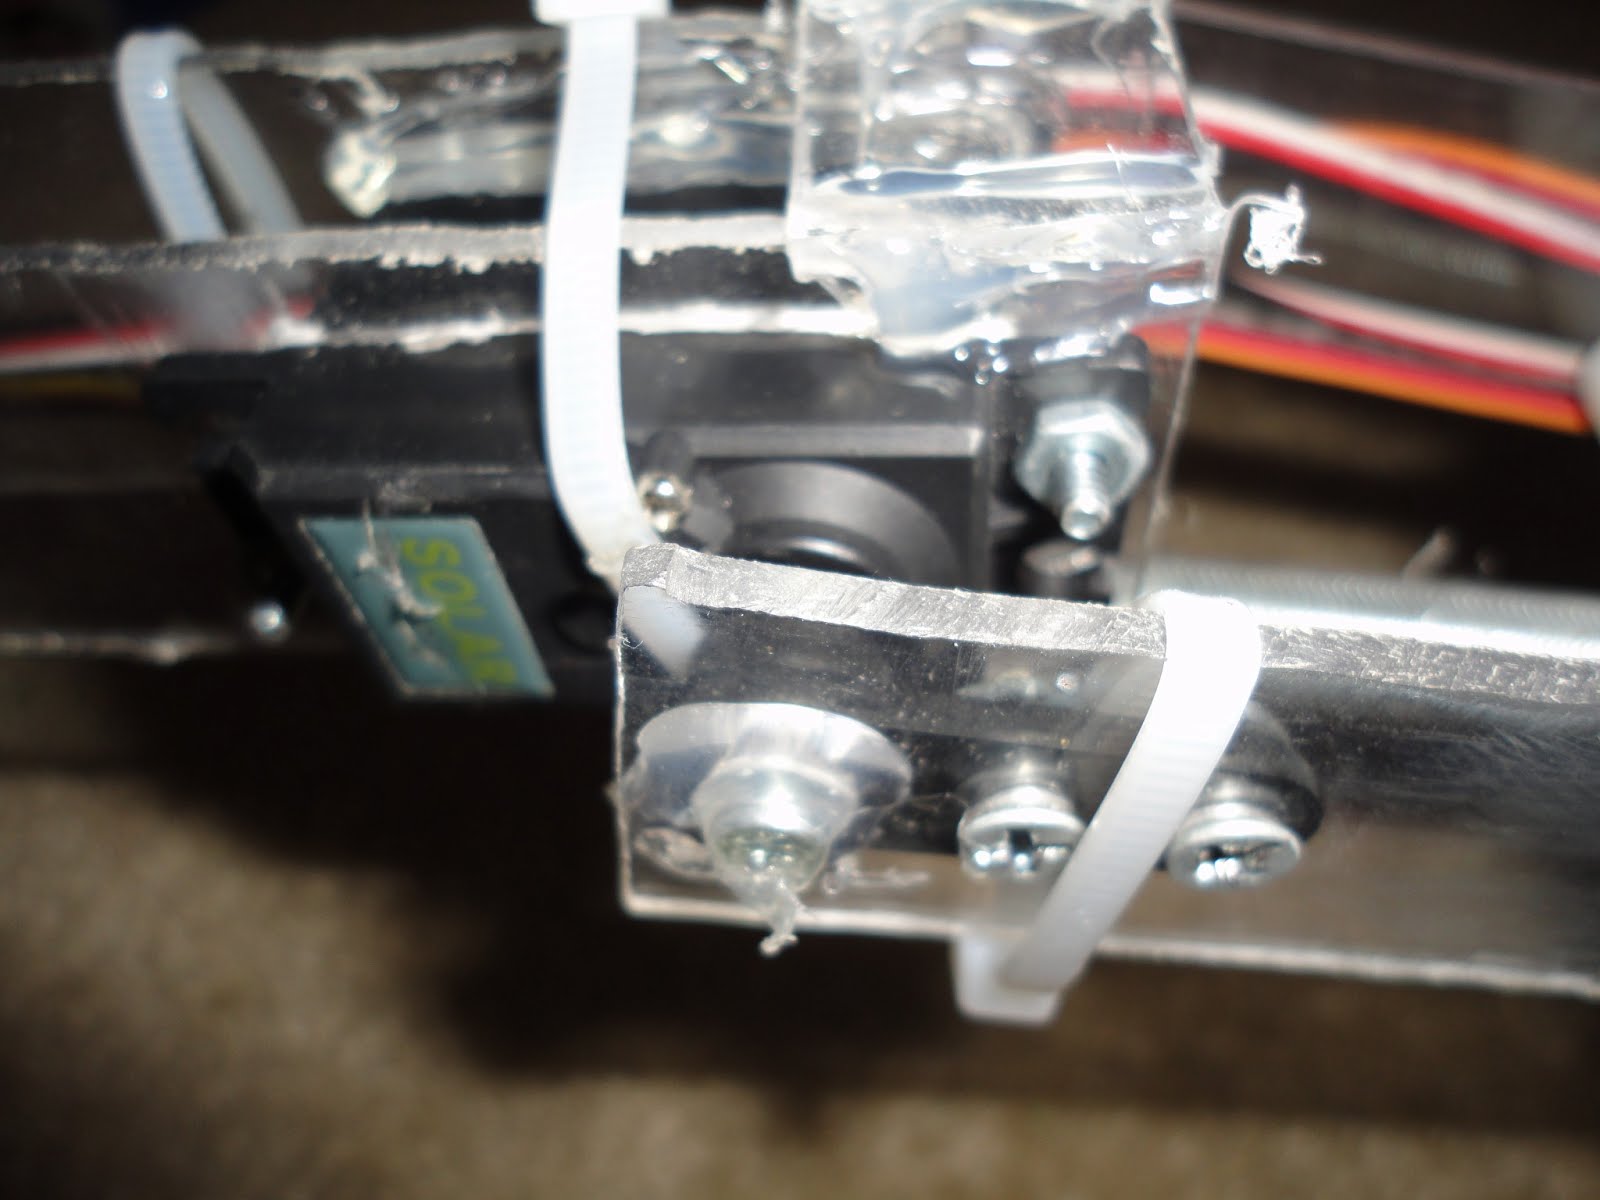
Most of the arm was built from Lexan polycarbonate because it could be cut and bent with ordinary shop tools. The rotating base used aluminum, plywood, a lazy-susan bearing, and a high-range servo, with an iron counterweight at the rear.
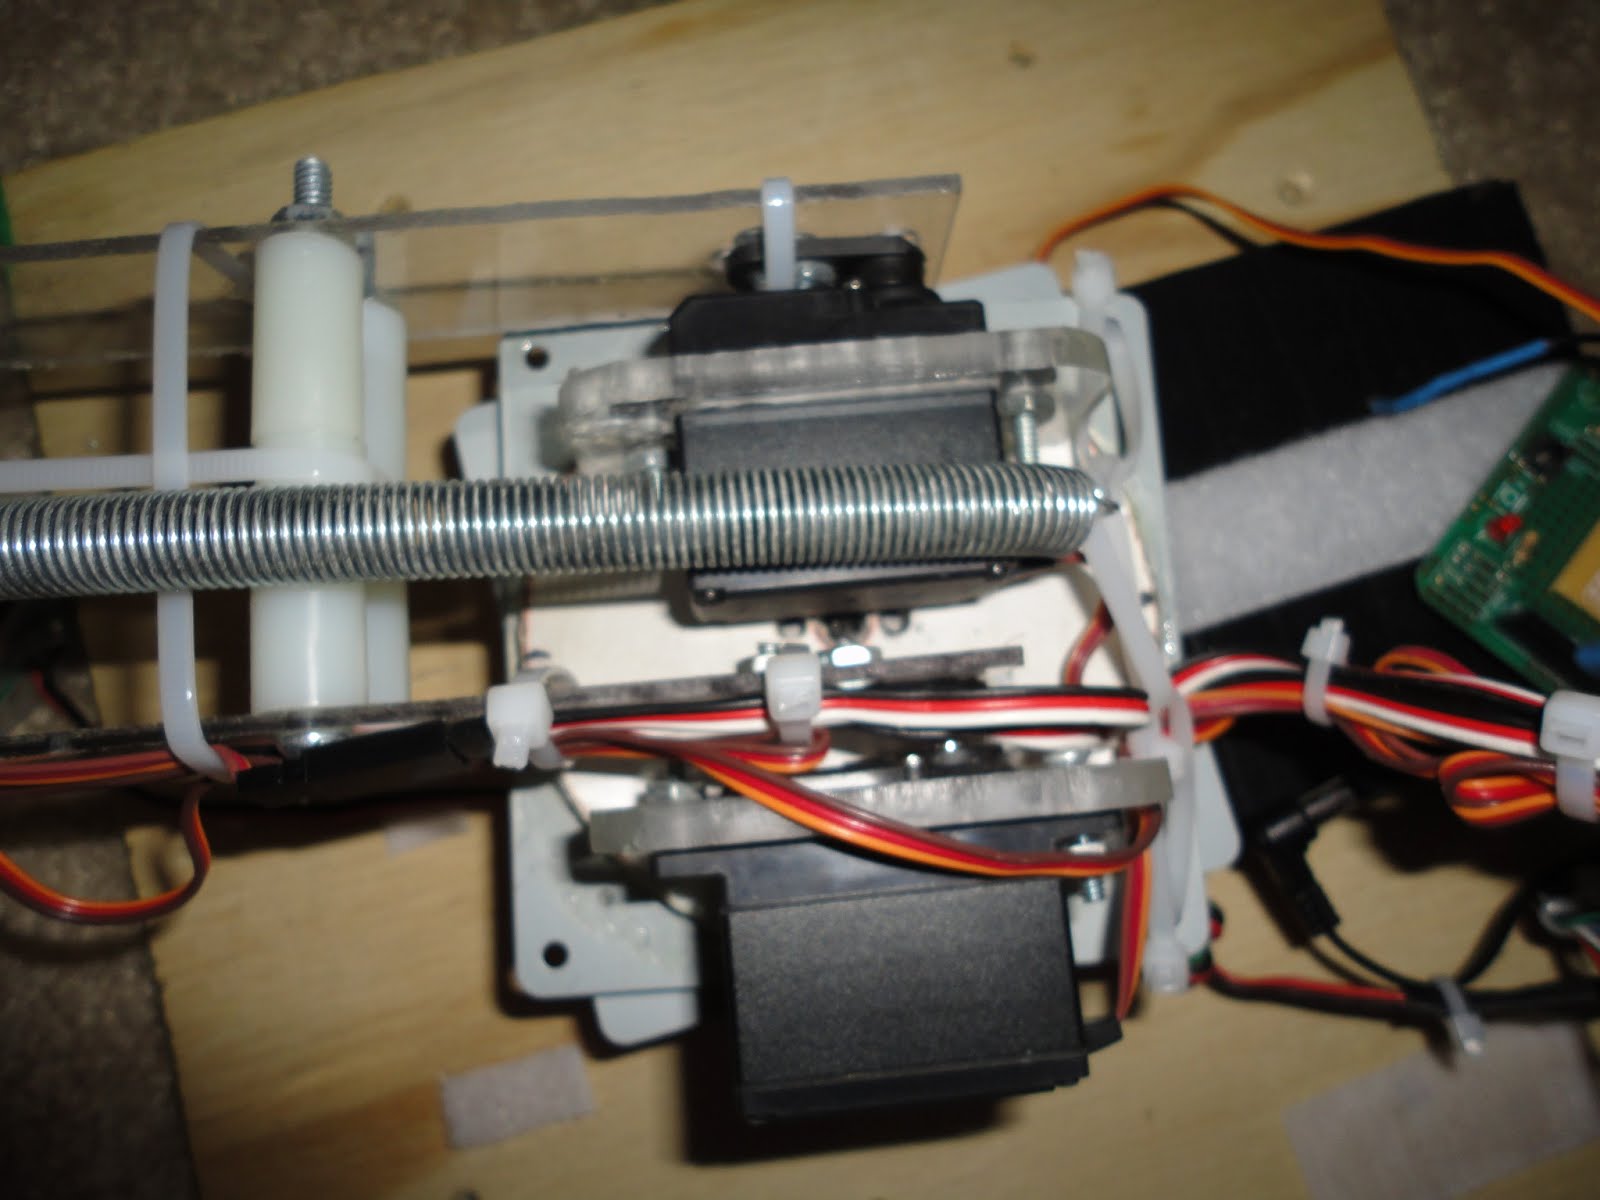
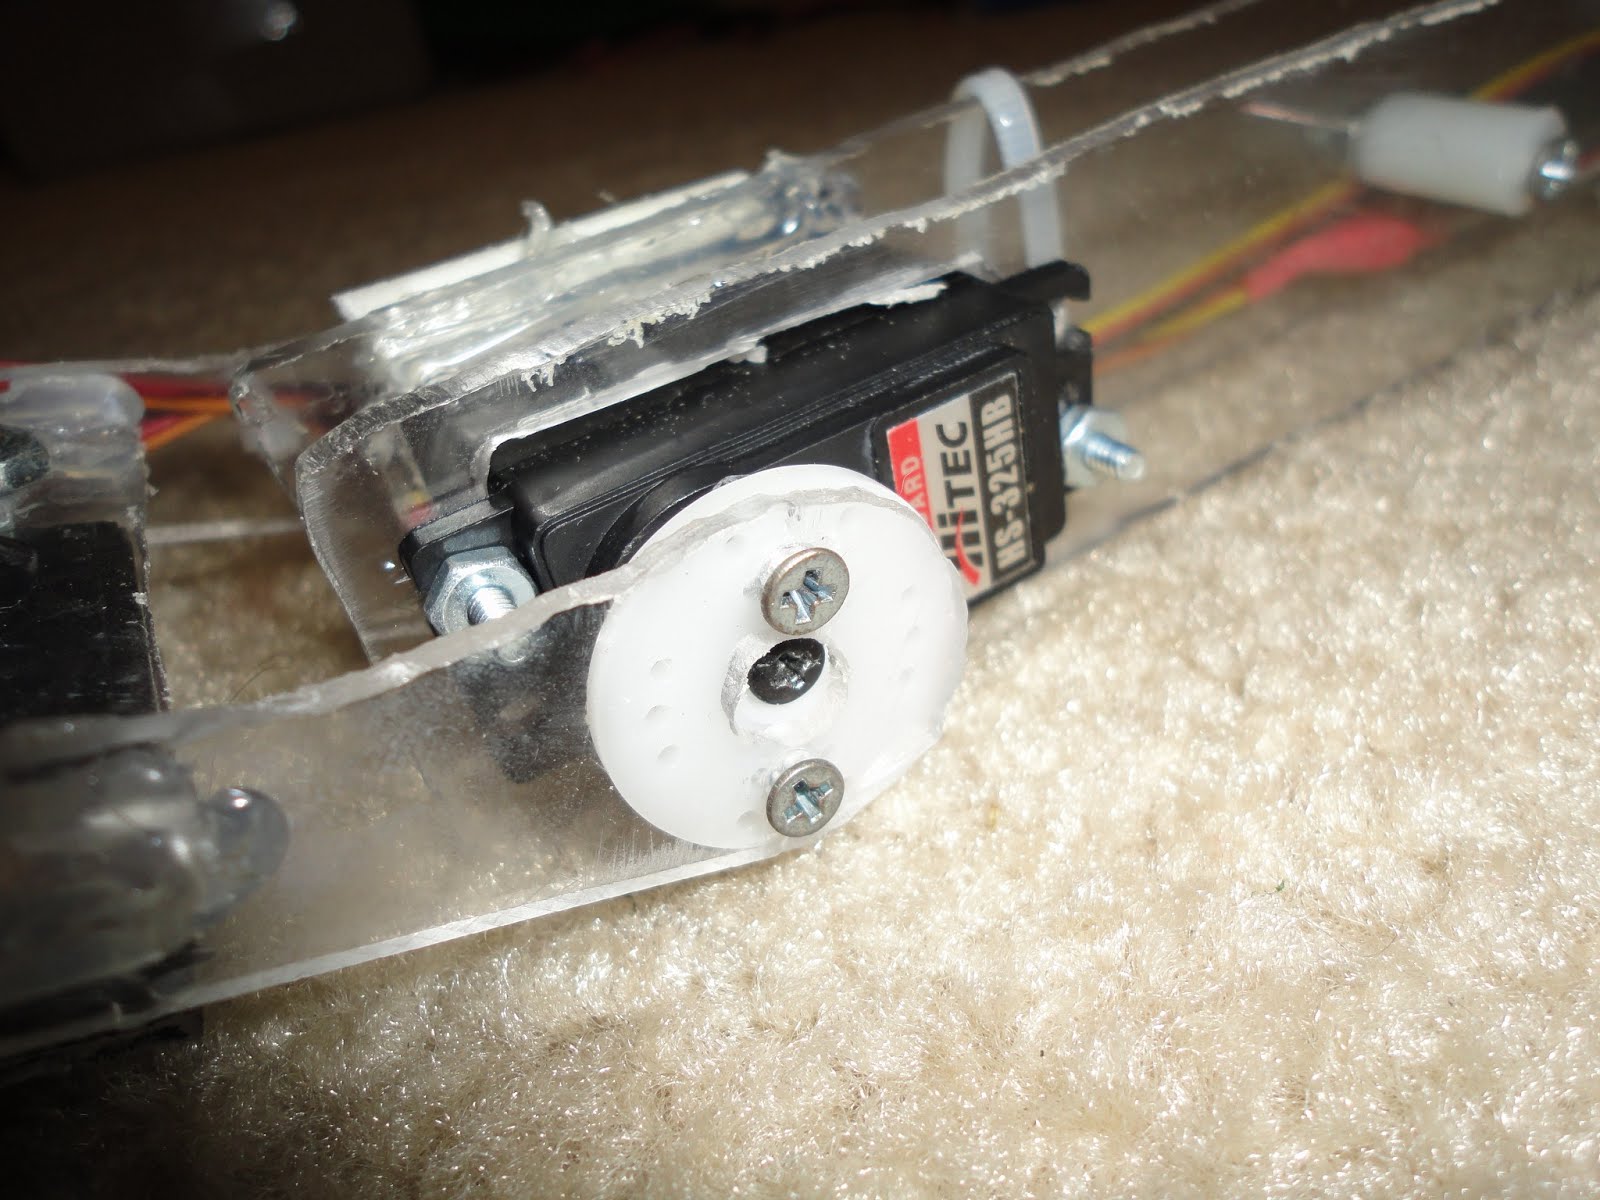
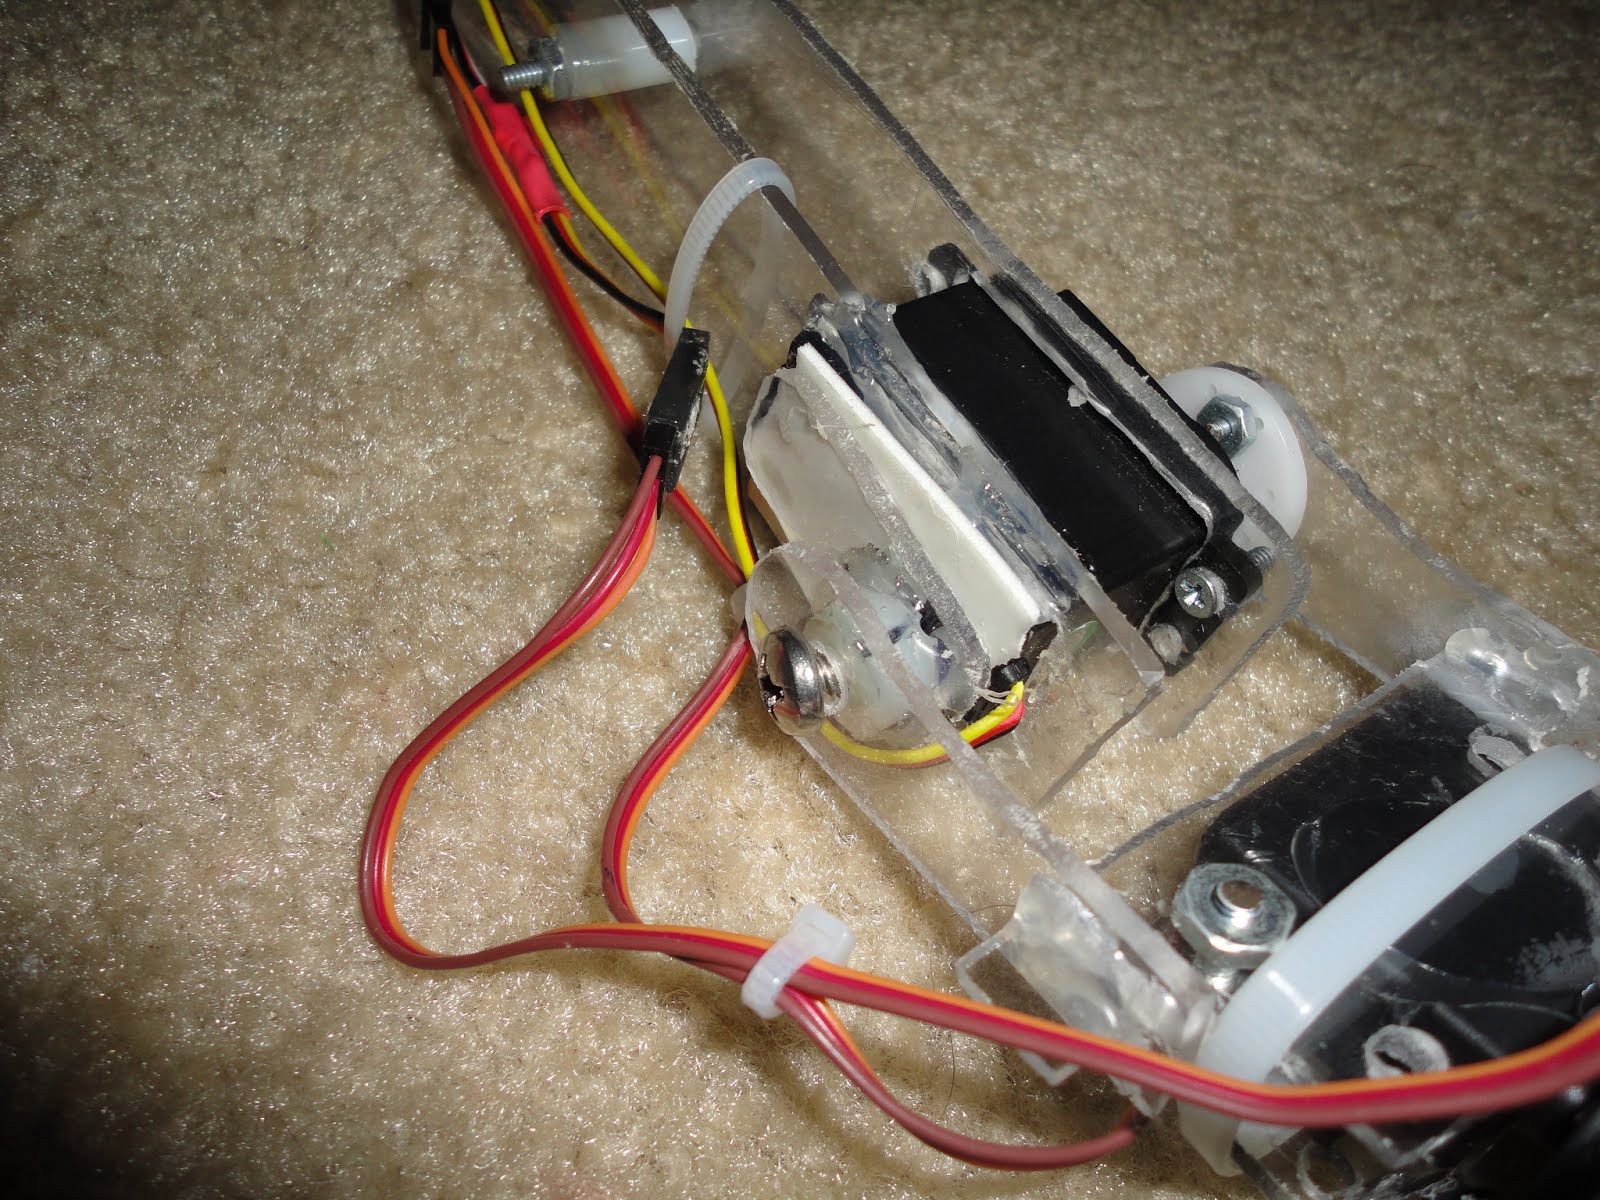
The paired base-joint servos had to be aligned so they would not work against each other. Slotted mounting holes and a spring reduced load on the base and elbow joints, while nylon spacers and ties kept the two sides of the arm from twisting.
Power and control
A three-cell 11.1 V lithium-polymer battery powered the machine through a 5 V / 6 V switching regulator rated for 8 A continuous output. The regulator supplied the servos and microcontroller.